🇺🇸Camarillo Polyhouse
LiveSiteCamarillo, California
Rows · area18 rows · 5,200 m²
RobotsEve-01 Charlie
CropStrawberry · Monterey
SinceMar 2026
Booking 2026 commercial pilots. Three sites live: Marneuli, Camarillo, Telavi.
Request a pilot →EVE-01 is a dual-arm harvesting robot for protected strawberry. It reports into the NeuraPick platform, which runs the rest of the greenhouse: every row on a map, crop scouting, environment control, inputs and inventory, work orders, and a debug console for the engineer. Everything runs on site. In field trials since February 2026.
Two independent arms, a stereo camera stack, a 48 V drivetrain and fifteen vision models, all running on the robot.
This is the sheet a grower should argue with. Every number below was measured in Block A, Marneuli, and the same configuration is running in Camarillo and Telavi.


| Metric | Specification |
|---|---|
| ManipulationTwo arms work the same gutter from both sides. Each end effector is modelled on surgical instruments: a cable-driven jaw holds the fruit while a blade cuts the calyx. Clean cut, intact shelf life. | |
| Arms | 2 · independent |
| Pick cycle | 3 – 4 s per arm |
| Throughput | ~600 picks · arm · h · 1,200+ combined |
| End effector | Cable-driven jaw + calyx blade |
| PerceptionOne stereo camera per arm gives RGB and depth in a single pipeline. Every model the robot needs runs on the camera and the robot itself. Nothing leaves the greenhouse to decide a pick. | |
| Sensor | OAK 4D · stereo RGB-D |
| Depth precision | ±2 mm at 0.5 m |
| Detection latency | 16 ms · 60 fps |
| Inference | On-device · NVIDIA Jetson |
| Vision models | 15 · all on the robot |
| MobilityDifferential drive with an independent steering axis, geared for narrow aisles. The robot crawls at 0.1 m/s while picking and moves between rows at walking pace. | |
| Harvest speed | 0.1 m/s |
| Transit speed | 80 m/min |
| Payload | 400 kg |
| Power & environmentAll-electric, with a pack that swaps hot. Rated for a wet, dusty greenhouse. | |
| System | 48 V all-electric |
| Runtime | ~6 h continuous · hot-swap pack |
| Protection | IP65 |
| Operating temperature | 5 – 40 °C |
| Software & controlROS 2 end to end. A radio override publishes straight to the base; a tri-state switch is the e-stop. | |
| Stack | ROS 2 Humble · Nav2 · MoveIt 2 |
| Manual override | ELRS · RadioMaster TX16S Mk II |
| E-stop | Tri-state switch |
No round trip to a server, no queue, no single point of failure. Four stages, each with a time budget the robot keeps.
Stereo cameras capture colour and depth at 60 frames per second, fused into one point cloud.
Each berry is found, graded for ripeness, given a pick pose and a priority.
Collision-free arm trajectories, coordinated with the base as it crawls along the gutter.
The jaw closes, the blade cuts the calyx, the berry goes to the tray. One motion.

A 50-metre row, picked clean in under 9 minutes.
EVE-01 reports into the NeuraPick platform: a complete greenhouse management and environment control system. Every row on a map, crop scouting and treatments, climate, CO₂ and fertigation, inputs and inventory, work orders for the crew, and a debug console for the engineer. The six screens below are the platform's own, for the facility selected in the topbar.
· demo dataset: row composition, positions and findings are illustrative. Fields, layout and behaviour are the platform's own.
Sprays, dripline repairs, sanitation, calibration, receiving. A work order is created from a scout finding or a robot fault in one click, assigned to a crew with an hour estimate, and closed with what it actually took.
· demo dataset: orders, crews and dates are illustrative. Fields, layout and behaviour are the platform's own.
EVE-01 writes a per-plant health record as it picks. Disease and pest detection run on the same cameras and the same on-robot compute. The console shows only what needs attention.
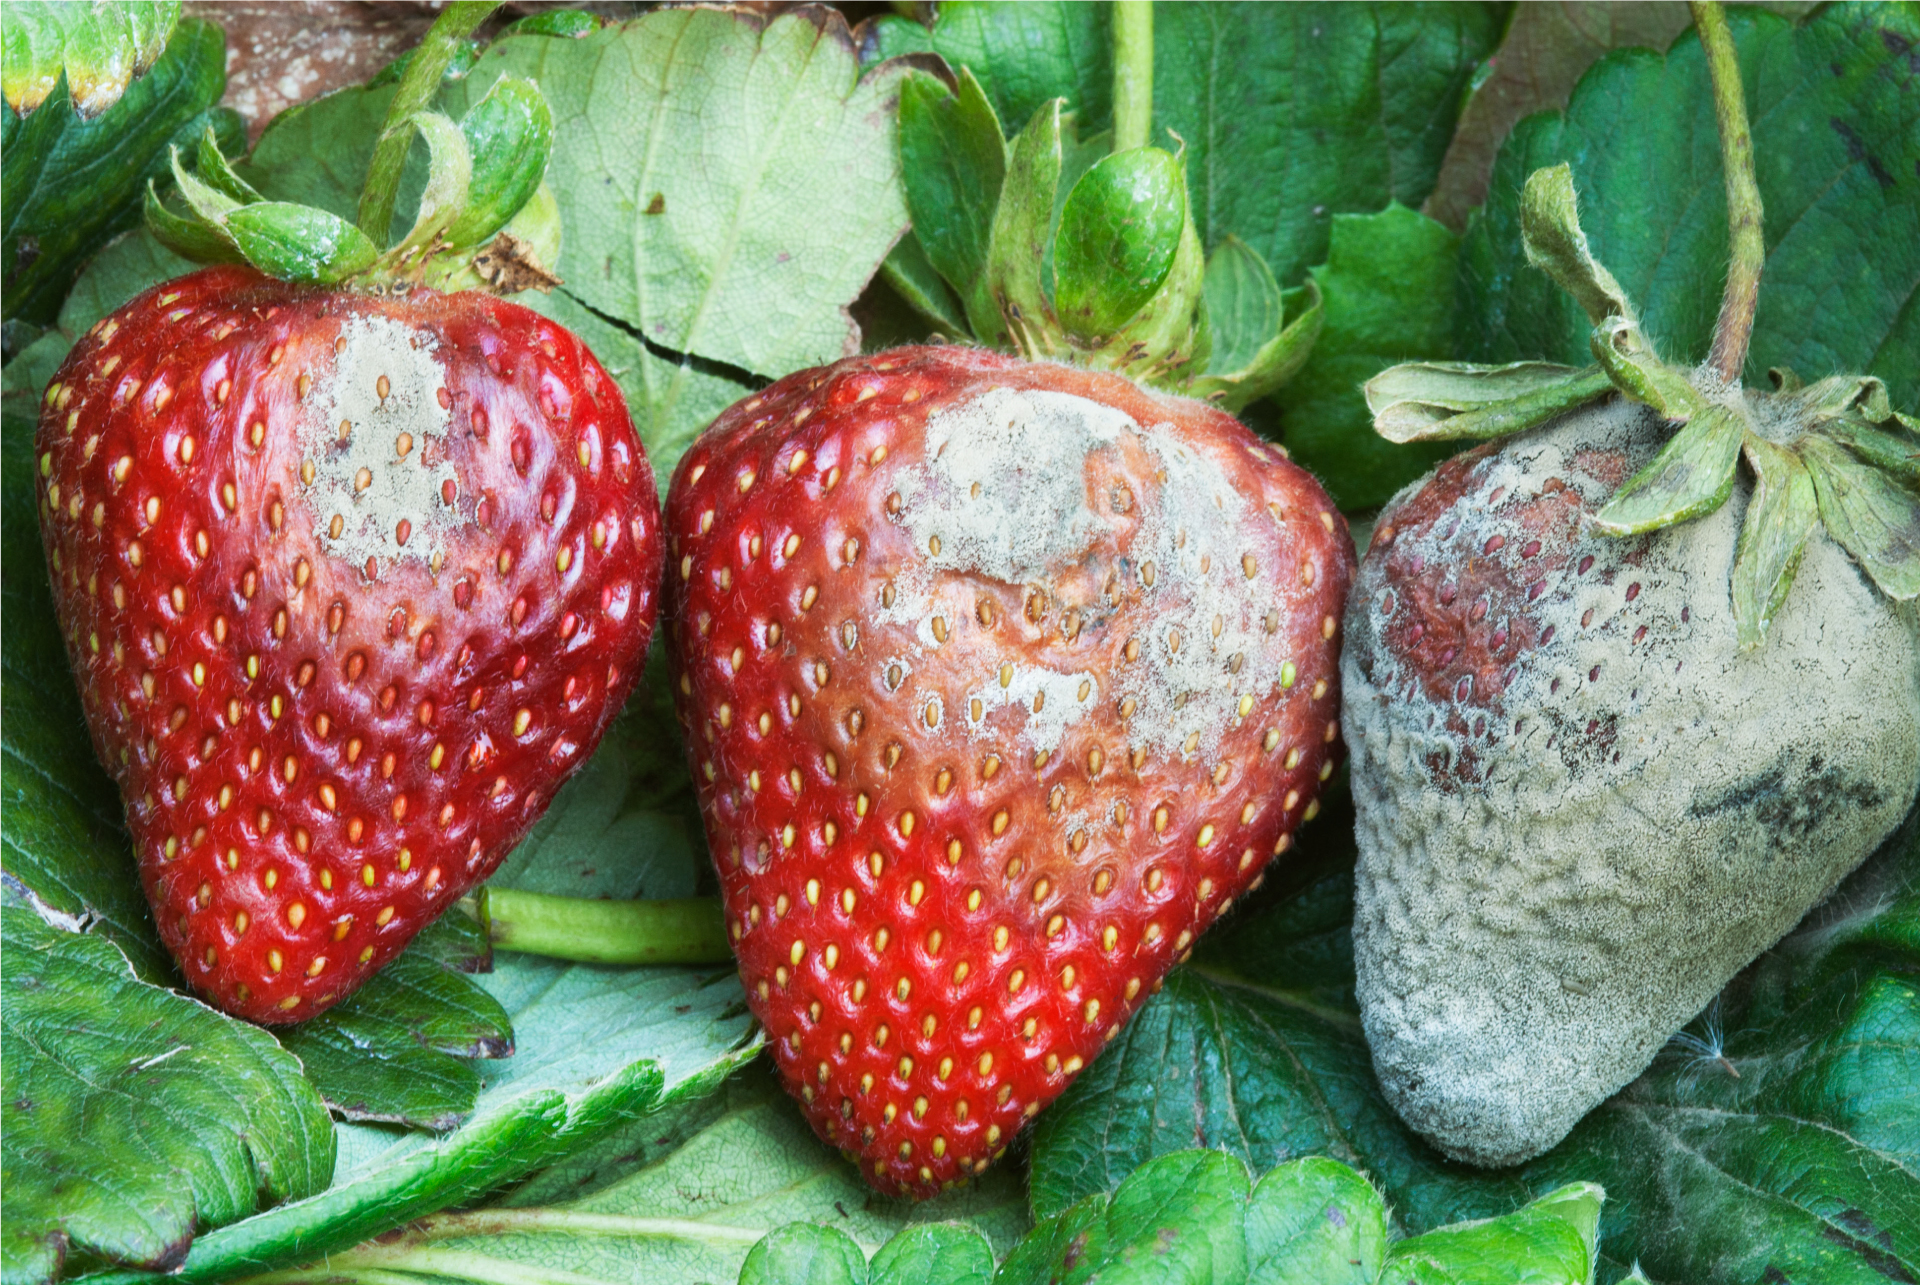
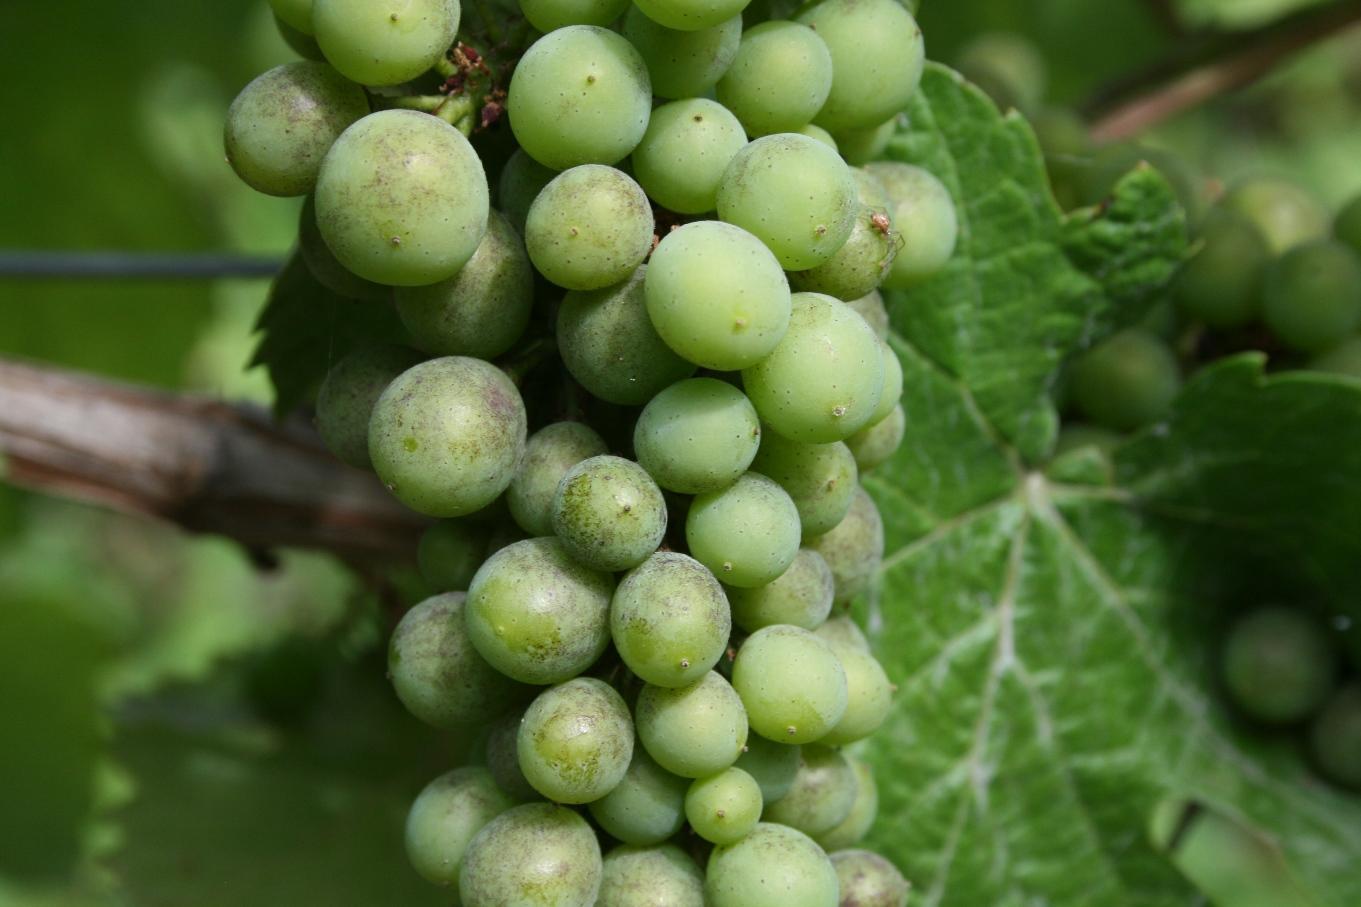
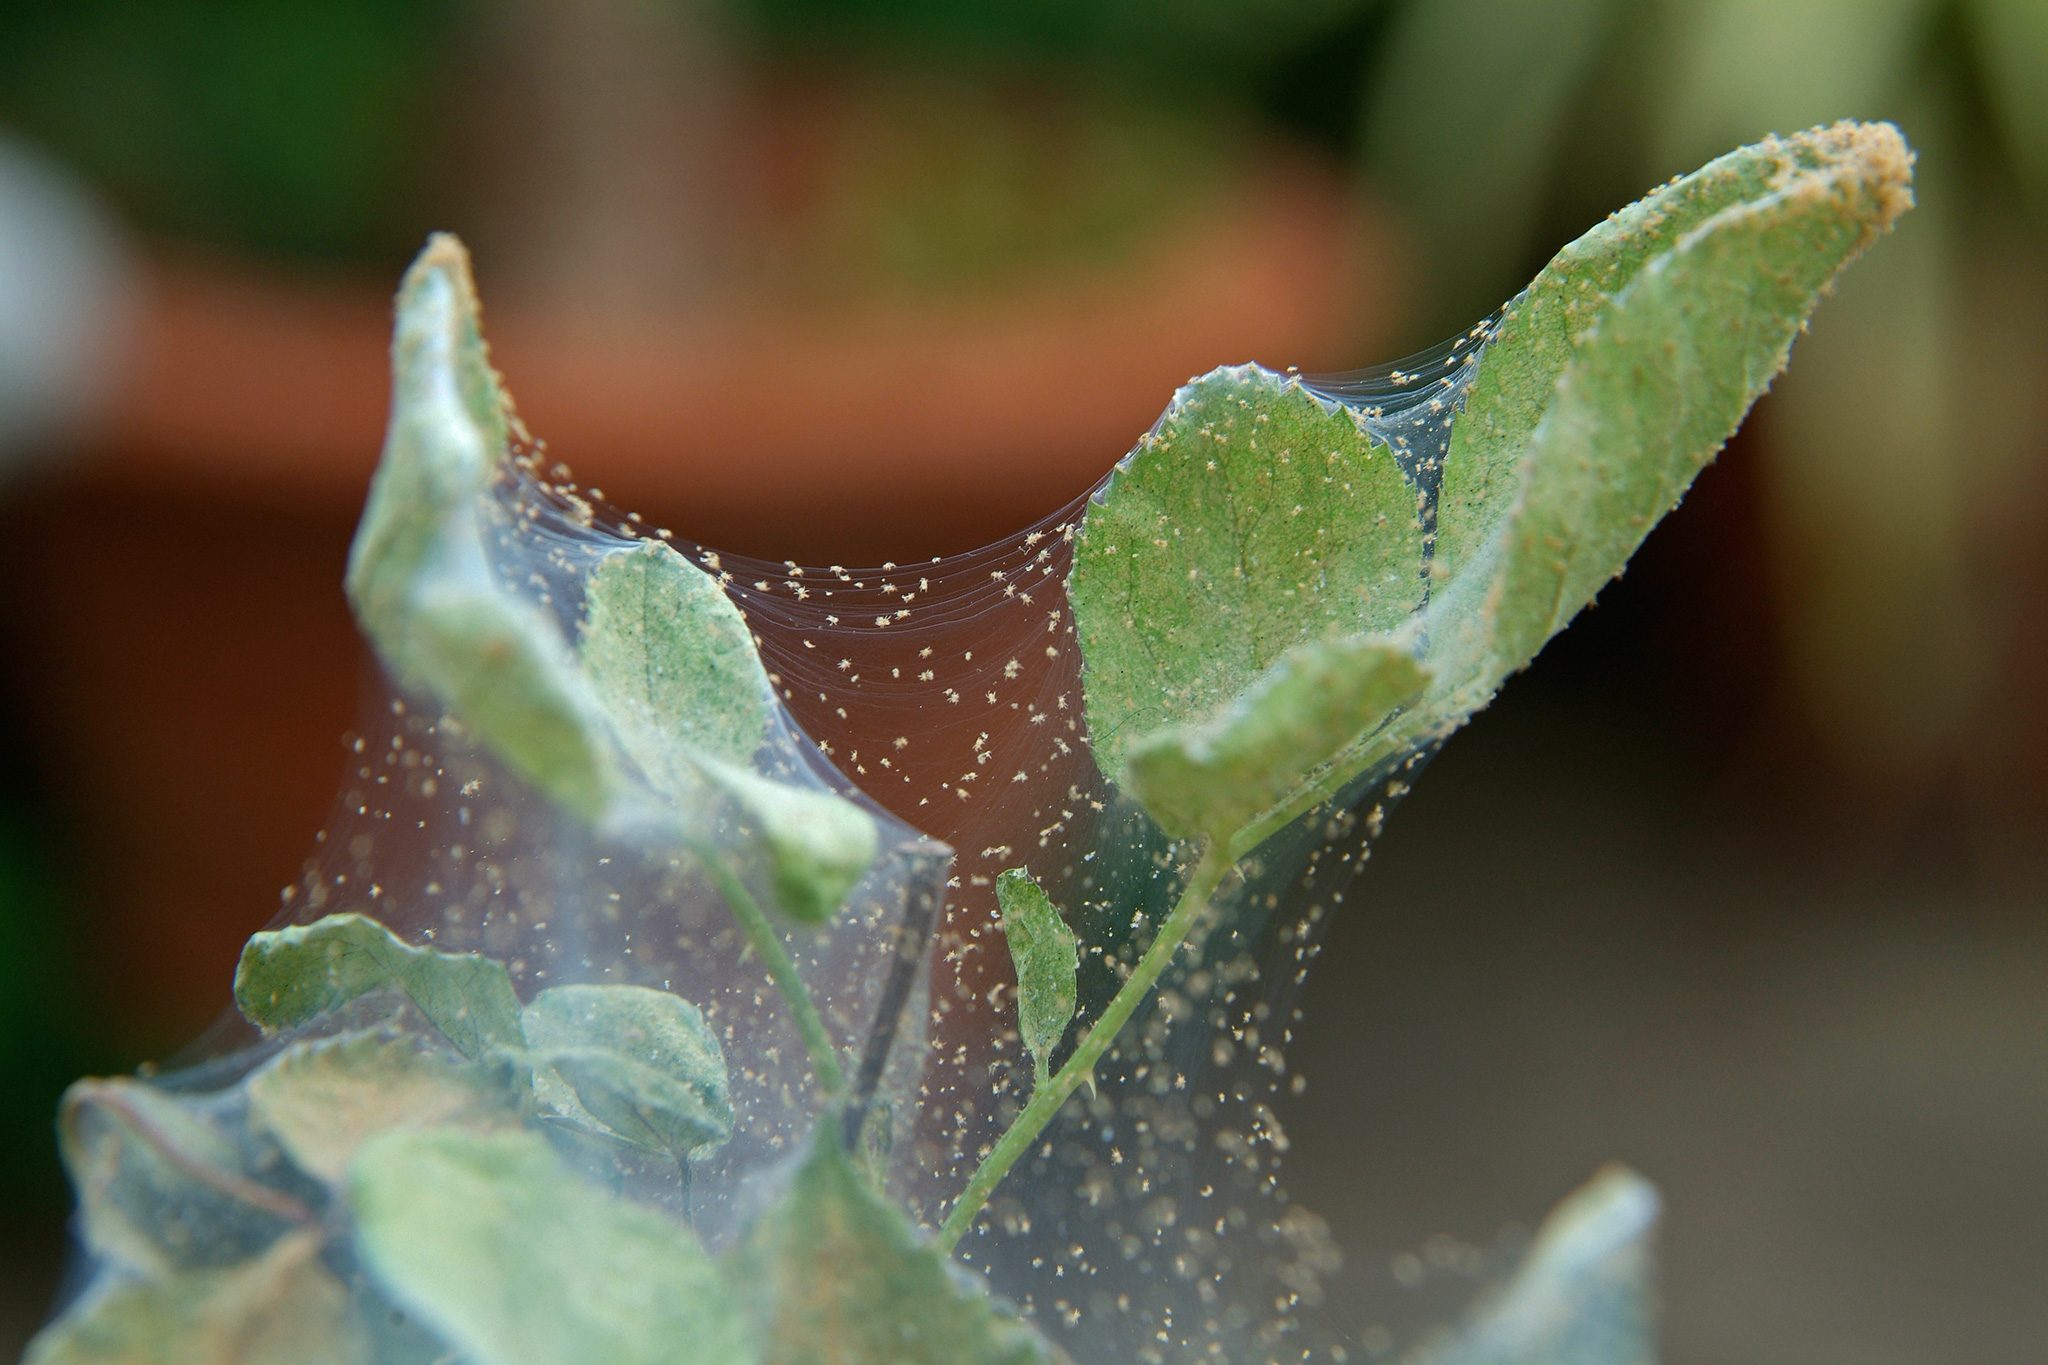
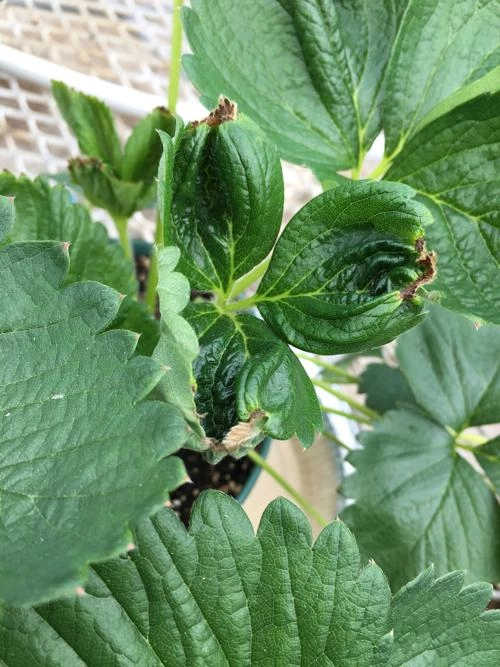
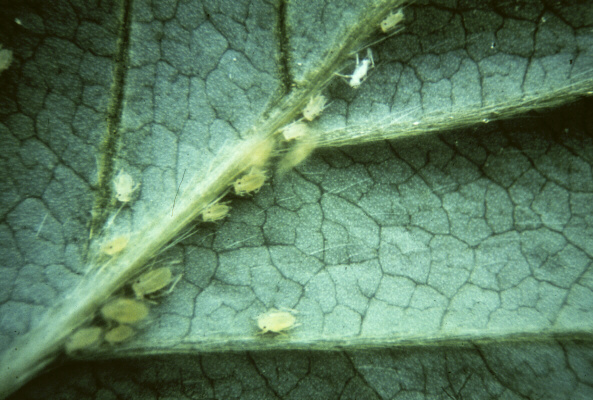
· demo dataset: findings, plans and dates are illustrative. Fields, layout and behaviour are the platform's own.
The platform runs the greenhouse environment the way a climate computer does: per-compartment heating and venting setpoints, humidity and CO₂ limits, shade and energy screens, fogging, and radiation-driven irrigation shots with drain and EC feedback. Sensors, actuators and alarms sit next to the robots that work the rows.
· demo dataset: readings, setpoints and alarms are illustrative. Fields, layout and behaviour are the platform's own.
Crop protection, fertilizer, biocontrols, packaging and robot spares in one stock list. Reserved quantities come from open work orders, a low line raises a reorder, and a spray issued from stock is written to the treatment record and the punnet QR.
· demo dataset: stock levels, lots and values are illustrative. Fields, layout and behaviour are the platform's own.
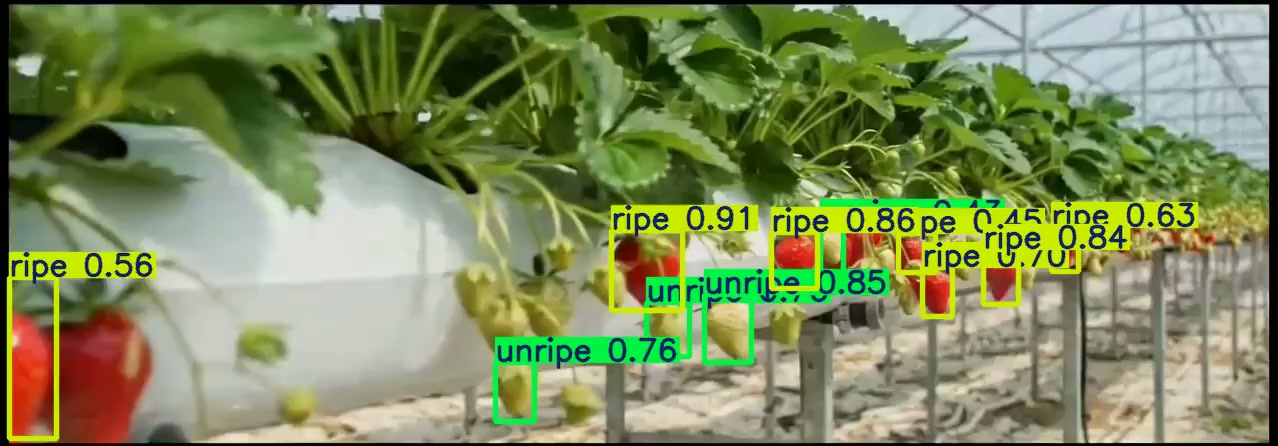
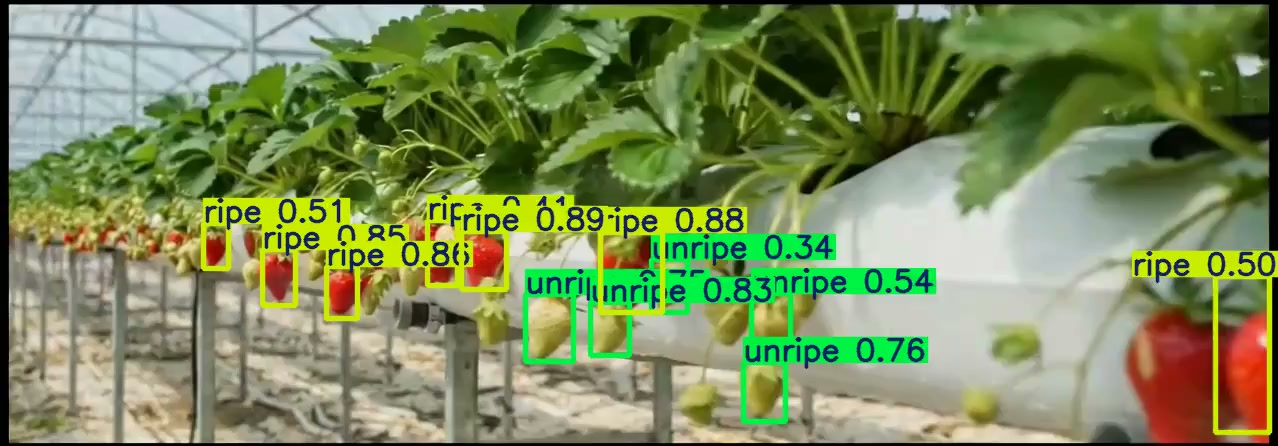
The same console opens the robot up: live topics and rates, both arm cameras, the fused point cloud, battery and drive plots, diagnostics by level, and a recording you can scrub. No laptop plugged into the robot.
 REC
 REC
· demo dataset: topics, plots and diagnostics are illustrative. Fields, layout and behaviour are the platform's own.
Each tray leaving an EVE-01-managed greenhouse carries a code that opens its origin record: the exact row, the pick day, and the treatments behind it, from flower to punnet.


Every trial pairs the hardware with operator training and a NeuraPick engineer on call. Growers get the console, the scouting record and the punnet codes from the first row.
We didn't set out to build the cleverest robot. We set out to build the one that shows up tomorrow morning, and the morning after that. In a working greenhouse that is the only thing that matters.
Greenhouses lose Wi-Fi. Every inference, every plan and every fail-safe runs on the robot. The cloud is optional.
Cable-driven actuation borrowed from surgical robotics. The fruit is held, not squeezed, and shelf life shows it.
A real e-stop, a real radio override, a real way to take the wheel. Robots that earn trust rather than demand it.
We are booking 2026 commercial pilots. Tell us about your operation and a NeuraPick engineer replies within 48 hours with a deployment plan for your rows.
Prefer email? pilots@neurapickrobotics.com